#include <string>#include <vector>#include <map>#include <stdint.h>#include <Eigen/Core>#include <Eigen/LU>#include <kdl/jntarray.hpp>#include <kdl/chainjnttojacsolver.hpp>#include <cob_twist_controller/TwistControllerConfig.h>
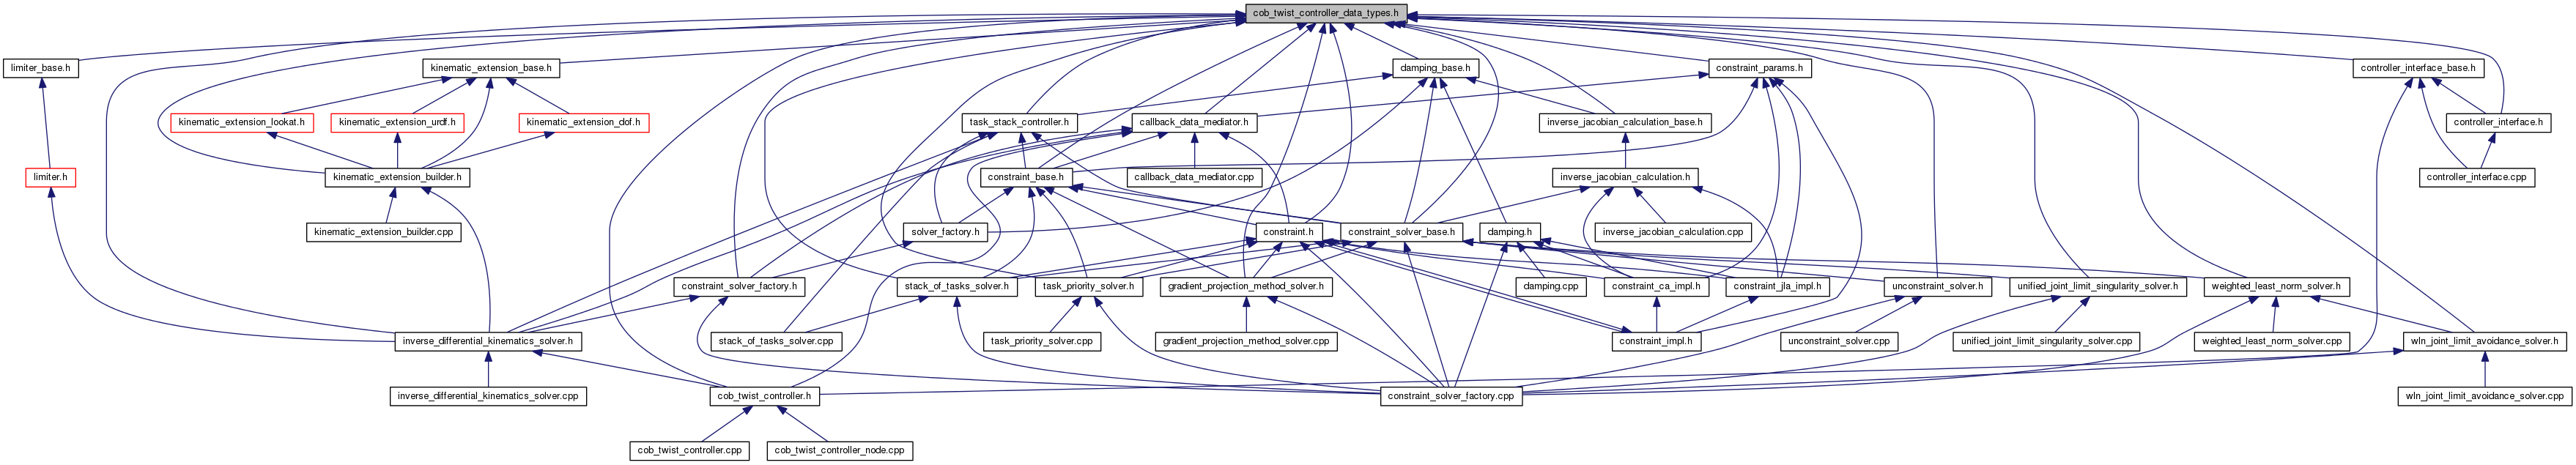
Go to the source code of this file.
Classes | |
| struct | ActiveCartesianDimension |
| struct | ConstraintParams |
| class | ConstraintState |
| struct | ConstraintThresholds |
| struct | JointStates |
| struct | LimiterParams |
| struct | LookatOffset |
| struct | ObstacleDistanceData |
| struct | TwistControllerParams |
| struct | UJSSolverParams |
Defines | |
| #define | DEFAULT_CYCLE 0.02 |
| #define | DIV0_SAFE 1.0e-6 |
| #define | MAX_CRIT true |
| #define | MIN_CRIT false |
| #define | ZERO_THRESHOLD 1.0e-9 |
Typedefs | |
| typedef Eigen::Matrix< double, 6, Eigen::Dynamic > | Matrix6Xd_t |
| typedef std::map< std::string, std::vector < ObstacleDistanceData > > | ObstacleDistancesInfo_t |
| typedef Eigen::Matrix< double, 6, 1 > | Vector6d_t |
Enumerations | |
| enum | ConstraintTypes { CA, JLA } |
| enum | ConstraintTypesCA { CA_OFF = cob_twist_controller::TwistController_CA_OFF, CA_ON = cob_twist_controller::TwistController_CA } |
| enum | ConstraintTypesJLA { JLA_OFF = cob_twist_controller::TwistController_JLA_OFF, JLA_ON = cob_twist_controller::TwistController_JLA, JLA_MID_ON = cob_twist_controller::TwistController_JLA_MID, JLA_INEQ_ON = cob_twist_controller::TwistController_JLA_INEQ } |
| enum | DampingMethodTypes { NO_DAMPING = cob_twist_controller::TwistController_NO_DAMPING, CONSTANT = cob_twist_controller::TwistController_CONSTANT, MANIPULABILITY = cob_twist_controller::TwistController_MANIPULABILITY, LEAST_SINGULAR_VALUE = cob_twist_controller::TwistController_LEAST_SINGULAR_VALUE, SIGMOID = cob_twist_controller::TwistController_SIGMOID } |
| enum | EN_ConstraintStates { NORMAL = 0, DANGER, CRITICAL } |
| enum | KinematicExtensionTypes { NO_EXTENSION = cob_twist_controller::TwistController_NO_EXTENSION, BASE_COMPENSATION = cob_twist_controller::TwistController_BASE_COMPENSATION, BASE_ACTIVE = cob_twist_controller::TwistController_BASE_ACTIVE, COB_TORSO = cob_twist_controller::TwistController_COB_TORSO, LOOKAT = cob_twist_controller::TwistController_LOOKAT } |
| enum | LookatAxisTypes { X_POSITIVE, Y_POSITIVE, Z_POSITIVE, X_NEGATIVE, Y_NEGATIVE, Z_NEGATIVE } |
| enum | SolverTypes { DEFAULT_SOLVER = cob_twist_controller::TwistController_DEFAULT_SOLVER, WLN = cob_twist_controller::TwistController_WLN, GPM = cob_twist_controller::TwistController_GPM, STACK_OF_TASKS = cob_twist_controller::TwistController_STACK_OF_TASKS, TASK_2ND_PRIO = cob_twist_controller::TwistController_TASK_2ND_PRIO, UNIFIED_JLA_SA = cob_twist_controller::TwistController_UNIFIED_JLA_SA } |
Define Documentation
| #define DEFAULT_CYCLE 0.02 |
Definition at line 33 of file cob_twist_controller_data_types.h.
| #define DIV0_SAFE 1.0e-6 |
Definition at line 35 of file cob_twist_controller_data_types.h.
| #define MAX_CRIT true |
Definition at line 31 of file cob_twist_controller_data_types.h.
| #define MIN_CRIT false |
Definition at line 32 of file cob_twist_controller_data_types.h.
| #define ZERO_THRESHOLD 1.0e-9 |
Definition at line 34 of file cob_twist_controller_data_types.h.
Typedef Documentation
| typedef Eigen::Matrix<double, 6, Eigen::Dynamic> Matrix6Xd_t |
Definition at line 336 of file cob_twist_controller_data_types.h.
| typedef std::map<std::string, std::vector<ObstacleDistanceData> > ObstacleDistancesInfo_t |
Definition at line 338 of file cob_twist_controller_data_types.h.
| typedef Eigen::Matrix<double, 6, 1> Vector6d_t |
Definition at line 337 of file cob_twist_controller_data_types.h.
Enumeration Type Documentation
| enum ConstraintTypes |
Definition at line 156 of file cob_twist_controller_data_types.h.
| enum ConstraintTypesCA |
Definition at line 65 of file cob_twist_controller_data_types.h.
| enum ConstraintTypesJLA |
Definition at line 71 of file cob_twist_controller_data_types.h.
| enum DampingMethodTypes |
Definition at line 37 of file cob_twist_controller_data_types.h.
| enum EN_ConstraintStates |
Definition at line 294 of file cob_twist_controller_data_types.h.
Definition at line 46 of file cob_twist_controller_data_types.h.
| enum LookatAxisTypes |
Definition at line 79 of file cob_twist_controller_data_types.h.
| enum SolverTypes |
Definition at line 55 of file cob_twist_controller_data_types.h.